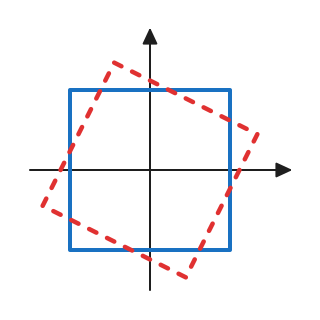
Die Drehung um den Nullpunkt mit Drehwinkel stellt eine lineare Abbildung dar. Die zugehörige Abbildungsmatrix ist die Drehmatrix Siehe auch Spiegelung Projektion 3D Im sind Rotationen wie folgt definiert: Misplaced &1 & 0 & 0 \\ 0 & \cos \phi & -\sin \phi \\ 0 & \sin \phi & \cos \phi }$$ $$R_Y(\phi) = \pmatrix{ \cos \phi & 0 & \sin \phi \\ 0 & 1 & 0 \\ -\sin \phi & 0 & \cos \phi }$$ $$R_Z(\phi) = \pmatrix{ \cos \phi & -\sin \phi & 0 \\ \sin \phi & \cos \phi & 0 \\ 0 & 0 & 1 }$$